bringing_in_wood crash, instances 309 and 310
Warm-up rerun of pt50, 2 envs in one sim, Oct 12 3:12 AM HST. Both envs stopped at about step 9000 (5 min of video) when PhysX returned NaN for a gripper finger pose.
AssertionError: left_gripper_finger_link1 orientation tensor([nan, nan, nan, nan]) is not a unit quaternion.
RuntimeError: Exception occurred during pre-physics step
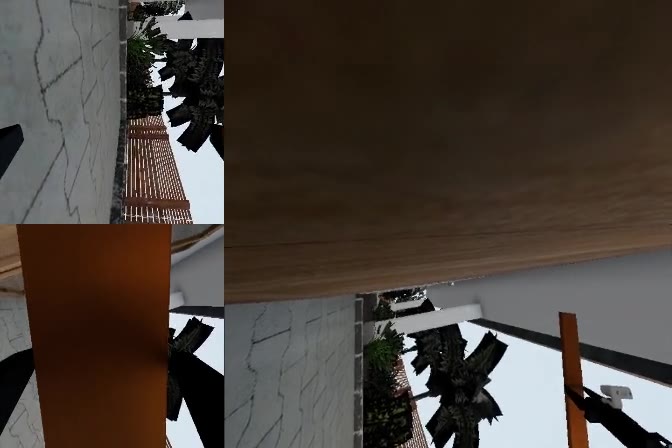
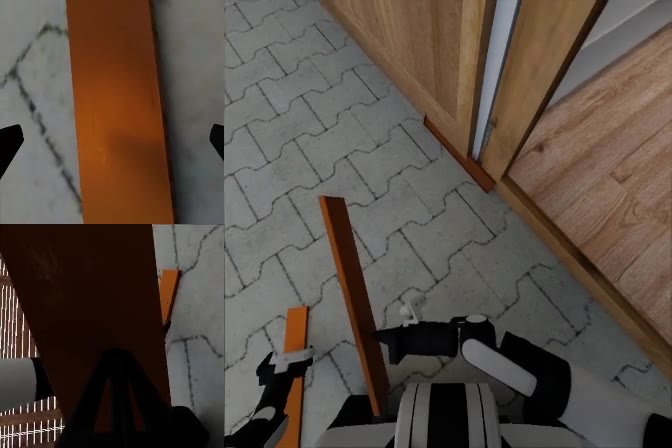
Each video shows the two wrist cameras stacked on the left and the head camera on the right. One video frame is one sim step.
Instance 309: the robot tips over
About 75 s in, the head camera swings to the sky and porch roof, rotated about 90 degrees, as if the robot fell onto its side. One wrist camera keeps a plank gripped the whole time. In the last 40 s the view slowly rolls, then goes nearly still with a wooden surface filling the top of the frame. A robot lying on its side with a plank clamped in its fingers is the kind of contact that makes the solver blow up, but the video can't show which contact failed.
Instance 310: a gripper pressed into a plank
The robot stands upright at an open doorway after carrying planks inside. One gripper holds a short plank vertically. The other is pressed into a long plank whose end rests on the floor, so the plank leans on the finger. It stays almost still for the last 40 s. That fits a finger contact blowing up, but it's inferred from the video. Since both envs share one physics scene, a blow-up in either one crashes both.
First 20 s, stock evaluator vs warm-up
The stock run starts turning about 2.5 s earlier, because the warm-up holds still for 2 requests. By 7 to 10 s the two runs look alike. No stock batch of bringing_in_wood was flagged stale, so here the fix only adds the short hold. The crash came about 5 minutes later and isn't related to it.
Scores on this task
| Instances | Stock Q | Warm-up Q |
|---|---|---|
| 301 to 308 | 0 | 0 |
| 309 | 0 | crashed, rerunning at seed 1 |
| 310 | 0.33 | crashed, rerunning at seed 1 |
pt50 scores 0 on almost all of this task either way, and every stock rollout used the full 20,304-step budget.